Qiming Star | Noitom Robotics' Tristan Dai: What Data Does Embodied Artificial Intelligence Actually Need?
I'll consider the GPT-3 moment for robotics to have arrived when my customers are no longer primarily professors and research leads.
Editor's Note: Over the past year, the industry's demand for training data has surged from thousands of hours to millions. But what robots lack isn't simply "more data" — it's data that models can actually learn from. In a recent conversation at AGI Playground 2026, Tristan Dai, founder and CEO of Noitom Robotics, shared his perspective from the data supply side on where the bottleneck really lies: R&D paths are reversing, with teams now identifying what data is available before designing models and hardware; modalities that today's models can't yet use are still worth capturing now; embodied AI's data needs have grown large enough to justify purpose-built capture hardware from scratch; and entering real-world environments means confronting the "impossible triangle" of cost, precision, and completeness. Dai, who has spent 15 years in motion capture, also offered a personal benchmark: "When my customers are no longer mostly professors and research leads, I'll know robotics has had its GPT-3 moment."
The following is an edited transcript of the conversation, republished with permission from the Qiming Venture Partners WeChat account.
Embodied AI is hot this year, but the hottest companies are data companies — everyone wants data.
Over the past year, industry demand for data scale has rapidly climbed from thousands of hours to hundreds of thousands or even millions of hours. Many robotics companies have begun building their own data factories, adding human videos, teleoperation trajectories, and synthetic data to their training sets. But as data volumes grow, people are discovering that what robots lack may not be simply "more data," but data that can describe real physical interactions, transfer across different robot embodiments, and be effectively learned by models.
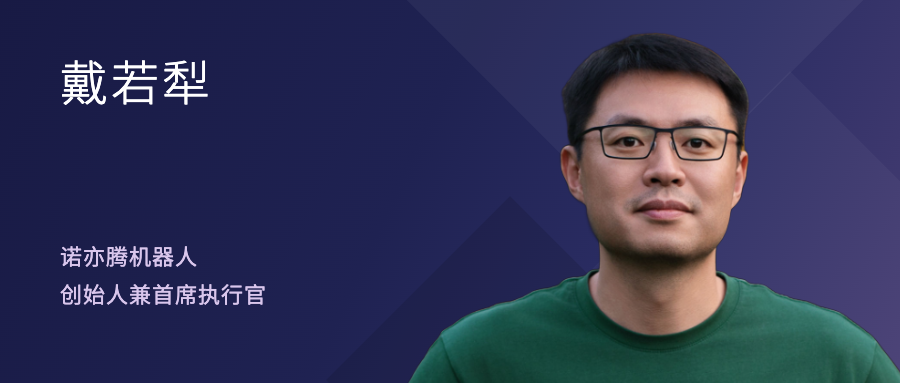
In a conversation at AGI Playground 2026, Tristan Dai, founder and CEO of Noitom Robotics, discussed where the real bottleneck in robotics data lies — from the perspective of a data supplier.
Dai has worked in motion capture for 15 years. He founded Noitom Robotics in 2025, focusing on data infrastructure for robotics and embodied AI. The team currently operates the ModalityNet data platform, building three human-centered multimodal datasets — OM, MOV, and ITW+ — that directly record human interactions in real-world environments. Demand-side users can map, retarget, or align these to different robot forms through reinforcement learning, rather than relying on traditional teleoperation.
The following are edited excerpts from the conversation.
01/
Data First, Then Models and Robots
Founder Park: Over the past two years, embodied AI's data requirements have grown from thousands of hours to hundreds of thousands or even millions of hours. Why?
Tristan Dai: The early approach was straightforward: assemble a humanoid robot from off-the-shelf parts, layer on a VLA or world-to-action model, then fill in data gaps as the system required.
Now that path is reversing. Teams first determine what data can provide the most complete information and whether it can be captured at scale, then design models around the available dataset, and finally design robot hardware around the model.
For example, lightweight multi-camera headsets can simultaneously capture egocentric video, hand pose, and body pose, and they have scaling potential. The industry's first phase solved "making robots move"; next comes generalization and high-dexterity manipulation, so the data problem has been pushed to the forefront.
Founder Park: One way the industry tries to close the gap is by adding modalities — force, touch, audio, depth. But do more modalities actually close the gap? Can today's foundation models even leverage these extra signals?
Tristan Dai: Humans never rely on vision alone during interaction. I can reach for my badge without looking because prior visual memory, proprioception, and touch are all in play. If we want robots to learn the same interactions, training data should preserve vision, touch, and accurate hand and body pose at minimum.
Today's models can't fully absorb all signals, but that doesn't mean we should discard them during capture. We're not fitting a specific current model architecture — we're preparing for the future. Audio may not be usable today, but it may record important interaction events. As long as the cost-benefit ratio makes sense, I'd rather preserve it now than have to recapture 100,000 hours of data a few years from now.
If information isn't recorded during capture, it's nearly impossible to recover from millions of hours of video later.
Founder Park: If you had an extra $100 million, would you put it toward better hardware, more modalities, or more real robot data from teleoperation?
Tristan Dai: I'd put most of it toward dedicated capture hardware. Embodied AI data demand has grown large enough to deserve purpose-built capture hardware designed from scratch.
If I were to allocate that $100 million specifically, I'd invest roughly $20 million in each modality: touch, egocentric vision, depth and high-precision 4D point clouds, ground-truth-level full-body pose, and hand pose with environment reconstruction. The goal is hardware that balances cost, precision, ease of use, low wearing burden, and battery life — ideally something that also provides value in ordinary people's daily lives, making them willing to wear it long-term and contribute data.
02/
Beyond Data Factories, Confronting the "Impossible Triangle"
Founder Park: Whether egocentric data or robot data, most is still produced in specially constructed environments rather than real nursing homes, warehouses, factories, or homes. What's blocking the industry from entering real deployment environments — technology, economics, or scene access?
Tristan Dai: It's an impossible triangle. Scaling capture in uncontrolled environments typically requires sacrificing precision or modal completeness. You can't build ten thousand different bathrooms in a data factory; to learn generalized cleaning, you eventually have to enter real homes, but many sensors simply can't be used there.
So we need new hardware: moving from outside-in tracking that relies on wall-mounted base stations to inside-out tracking, and unifying all signals into the same time domain and Cartesian coordinate system. There's no complete off-the-shelf solution available today.
Founder Park: What will be the next paradigm shift in robotics data? How far is the industry from its GPT-3 moment?
Tristan Dai: When my customers are no longer mostly professors and research leads, I'll consider that robotics' GPT-3 moment has arrived.
Today, even industry collaborations are essentially still research projects, with milestones measured in CoRL and ICRA papers rather than industrial deployment or revenue. My rough estimate: at least five more years.
Source | Founder Park Author | Li Yuan
Past Articles
Qiming Stars | Noitom Robotics Completes Pre-A+ Round Led by Qiming Venture Partners
Qiming Weekly | Top 10 News from Qiming Venture Partners Portfolio Companies Vol.34, 2026.11.3
Qiming Venture Partners was founded in 2006. The firm currently manages 11 USD funds and 7 RMB funds, with total assets under management reaching $9.5 billion. Since its inception, Qiming Venture Partners has focused on investing in early and growth-stage outstanding enterprises in Technology and Healthcare.
To date, Qiming Venture Partners has invested in over 630 high-growth innovative companies, of which more than 290 have listed on the New York Stock Exchange, NASDAQ, Hong Kong Exchanges and Clearing, Shanghai Stock Exchange, and Shenzhen Stock Exchange, or exited through M&A and other means. Over 110 portfolio companies have become recognized unicorns or super-unicorns.
Many Qiming Venture Partners portfolio companies have grown into the most influential companies in their respective fields, including Xiaomi (01810.HK), Meituan (03690.HK), Bilibili (NASDAQ:BILI, 09626.HK), Zhihu (NYSE:ZH, 02390.HK), Roborock (688169.SH), Hesai Technology (NASDAQ:HSAI, 02525.HK), UBTECH (09880.HK), WeRide (NASDAQ:WRD, 0800.HK), HyperStrong (688411.SH), Insta360 (688775.SH), Unisound (09678.HK), Biren Technology (06082.HK), Zhipu (02513.HK), Gan & Lee Pharmaceuticals (603087.SH), Tigermed (300347.SZ, 03347.HK), Zai Lab (NASDAQ:ZLAB, 09688.HK), CanSino Biologics (688185.SH, 06185.HK), Schrödinger (NASDAQ:SDGR), APT Medical (688617.SH), Sanyou Medical (688085.SH), AmoyDx (300685.SZ), Sinocelltech (688520.SH), Insilico Medicine (03696.HK), AusperBio, Yuanxin Technology, MediLink Therapeutics, Leads Biolabs, StepFun, and others.